Hand-in-Hand: Investigating Mechanical Tracking for User Identification in Cobot Interaction
Saad, A., Pascher, M., Kassem, K., Heger, R., Liebers, J., Schneegass, S. & Gruenefeld, U.
Proceedings of the 22nd International Conference on Mobile and Ubiquitous Multimedia, 2023
Summary
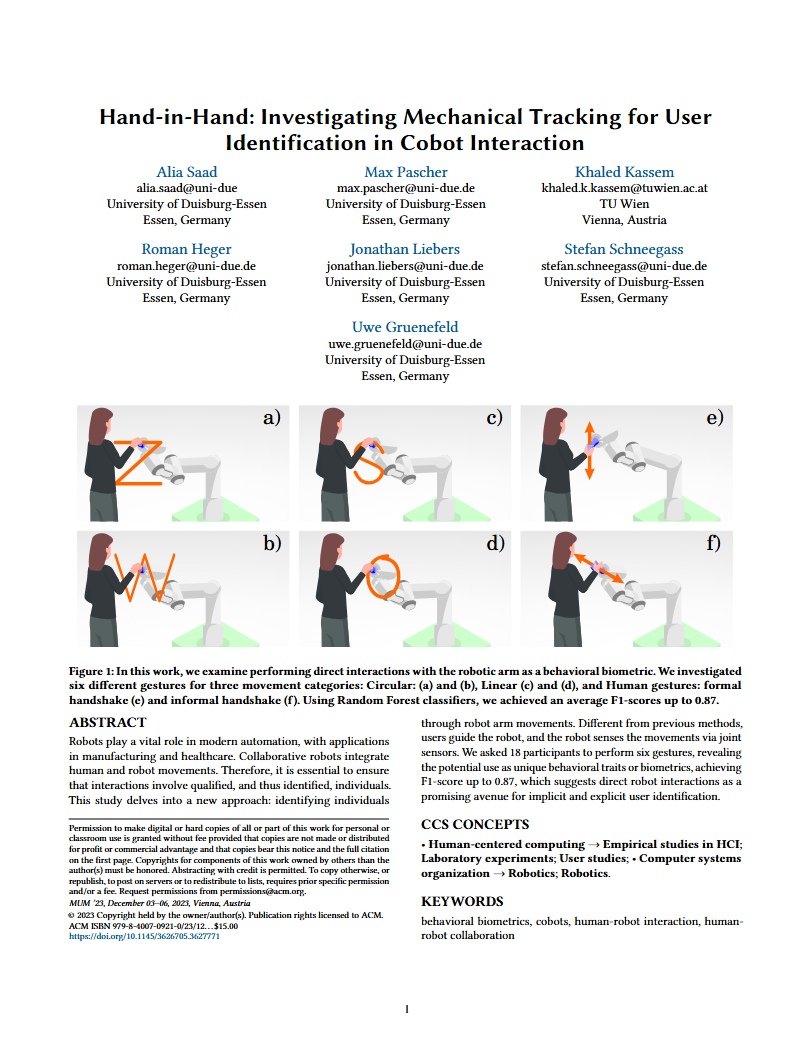
Robots play a vital role in modern automation, with applications in manufacturing and healthcare. Collaborative robots integrate human and robot movements. Therefore, it is essential to ensure that interactions involve qualified, and thus identified, individuals. This study delves into a new approach: identifying individuals through robot arm movements. Different from previous methods, users guide the robot, and the robot senses the movements via joint sensors. We asked 18 participants to perform six gestures, revealing the potential use as unique behavioral traits or biometrics, achieving F1-score up to 0.87, which suggests direct robot interactions as a promising avenue for implicit and explicit user identification.
Written for this site, the published abstract is at the DOI.
Cite as
Saad, A., Pascher, M., Kassem, K., Heger, R., Liebers, J., Schneegass, S. & Gruenefeld, U. (2023). Hand-in-Hand: Investigating Mechanical Tracking for User Identification in Cobot Interaction. In Proceedings of the 22nd International Conference on Mobile and Ubiquitous Multimedia (pp. 1–9). https://doi.org/10.1145/3626705.3627771